AI MACHINAE
Democratizing
physical AI.
Our mission is to bring an era of true abundance for all — by making the data, models and skills behind physical intelligence available to anyone who builds machines.
One platform for humanoids
The Data Wall
Hardware is
catching up.
Data is the wall.
As the hardware matures, we see data becoming the main barrier to entry for smaller players. A capable team can build a capable machine. What it can’t build alone is the years of real-world data that make the machine useful. We aspire to bring that wall down — and enable anyone to build, sell and be part of the physical AI economy.
01
Diverse capture
Our wearable capture kit plus compatible hardware from other companies — many people, many trades, many places.
02
Diverse machines
Our own machinae alongside hardware from anyone who builds to the platform. Every body adds to what the models know.
03
General intelligence
Diverse data generalizes best. We think it is the only route to true physical intelligence.
The Evidence
Diversity beats volume.
Our thesis isn’t a hunch. Recent robot-learning research keeps pointing the same way: varied people, places and machines teach more than piling up more of the same.
~90%
success in unseen environments with unseen objects, once training data spanned 32 environment–object pairs. Adding environments beat adding demonstrations.
Lin et al. — Data Scaling Laws in Imitation Learning for Robotic Manipulation (2024)
~3×
better performance on skills that existed only in other robots’ data, after pooling 22 robot types from 21 institutions into one training set.
Open X-Embodiment Collaboration — Open X-Embodiment: Robotic Learning Datasets and RT-X Models (2023)
~2×
performance in settings seen only in human video, once a model was pre-trained on enough scenes, tasks and embodiments. Learning from people emerged from diversity.
Kareer et al., Physical Intelligence — Emergence of Human to Robot Transfer in VLA Models (2025)
20,854 h
of first-person human video showed predictable log-linear scaling — and the better the model learned from people, the better a 22-DoF robot hand performed.
NVIDIA — EgoScale: Scaling Dexterous Manipulation with Diverse Egocentric Human Data (2026)
PUBLISHED RESEARCH BY THE GROUPS NAMED. AI MACHINAE IS NOT AFFILIATED WITH THEM.
The Platform
Capture. Learn. Deploy.
01
Capture
People wear capture gear that looks like ordinary clothing — ours, or compatible hardware from partners — while doing real work in real places.
02
Learn
NEXUM brings every stream into one schema, curates it, and trains foundation models built to transfer across embodiments.
03
Deploy
Capabilities ship as on-demand skills. Any machine built to the platform can call them — and every deployment feeds data back.
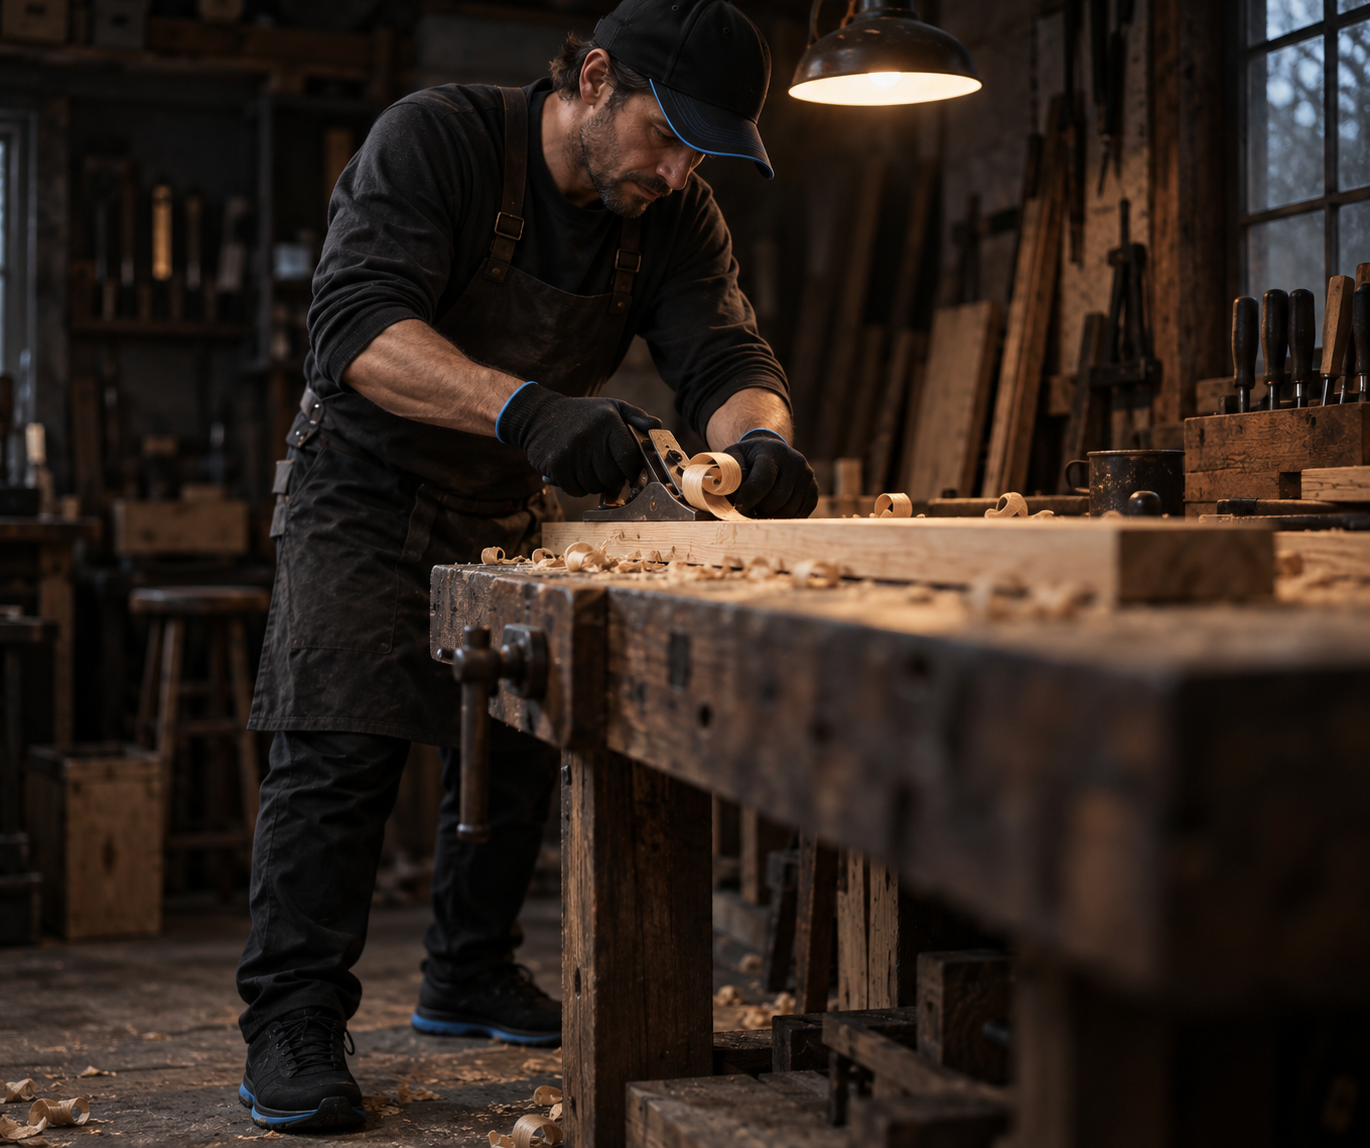
Capture
Worn, not mounted.
Data-collection hardware that looks and feels like ordinary clothing — so people can record real work, in real places, without changing how they do it.
VISUS
4 forward-facing cameras
TACTUS
Tactile sensors + joint encoders
GRESSUS
IMU
Get Involved
Three ways in.
For hardware makers
Ship the machine. Skip the data wall.
Build to the platform and launch with a dataset, models and a skill library you didn’t have to collect.
Build with us
For contributors
Your work, teaching the next machines.
Wear the capture kit while you do what you already do. Join the waitlist as the program opens.
Join the waitlist
For investors
The data layer for physical AI.
Pre-seed is open. See the thesis, the evidence behind it, and how the platform grows.
Investor overview
Machinae
Our own machines,
as reference hardware.
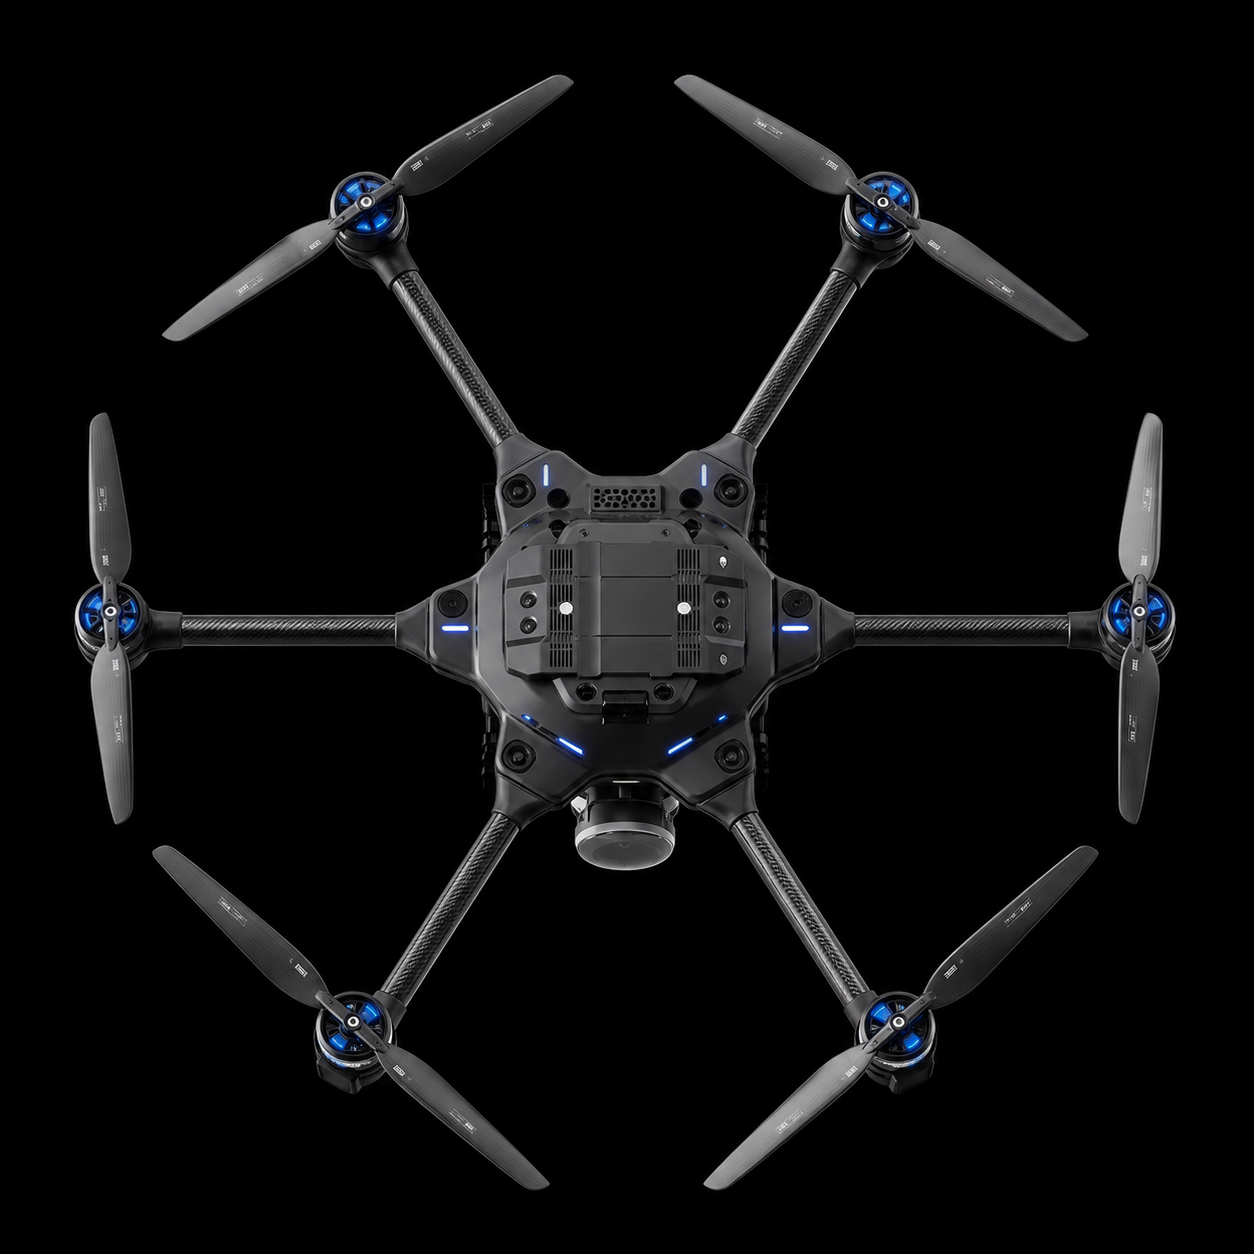
PROTOTYPE — MACHINA 001
IRIS V1
Autonomous survey hexacopter
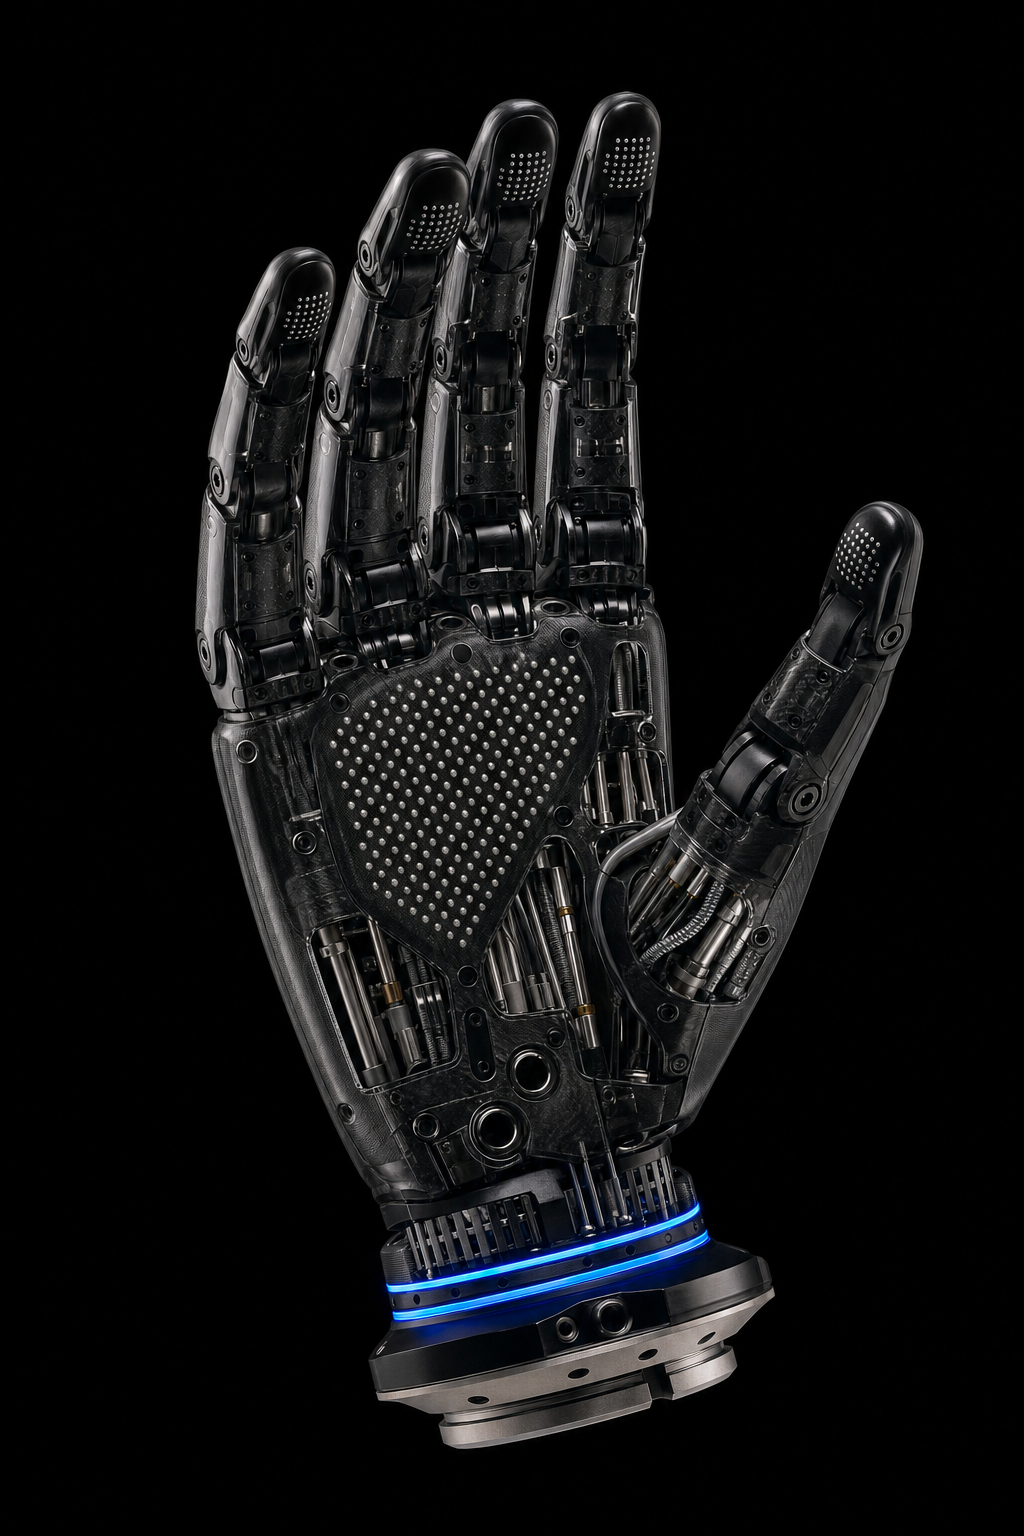
HAND IN DESIGN — MACHINA 005
FABER
Humanoid — FABER HAND first
FUTURE EMBODIMENT
VECTOR
FUTURE EMBODIMENT
FOSSOR
FUTURE EMBODIMENT
LUPUS