Machina 005
FABER
Humanoid Machina
FABER is our humanoid — reference hardware for the work people do with their hands: assembling, fastening, finishing, operating tools designed for human hands.
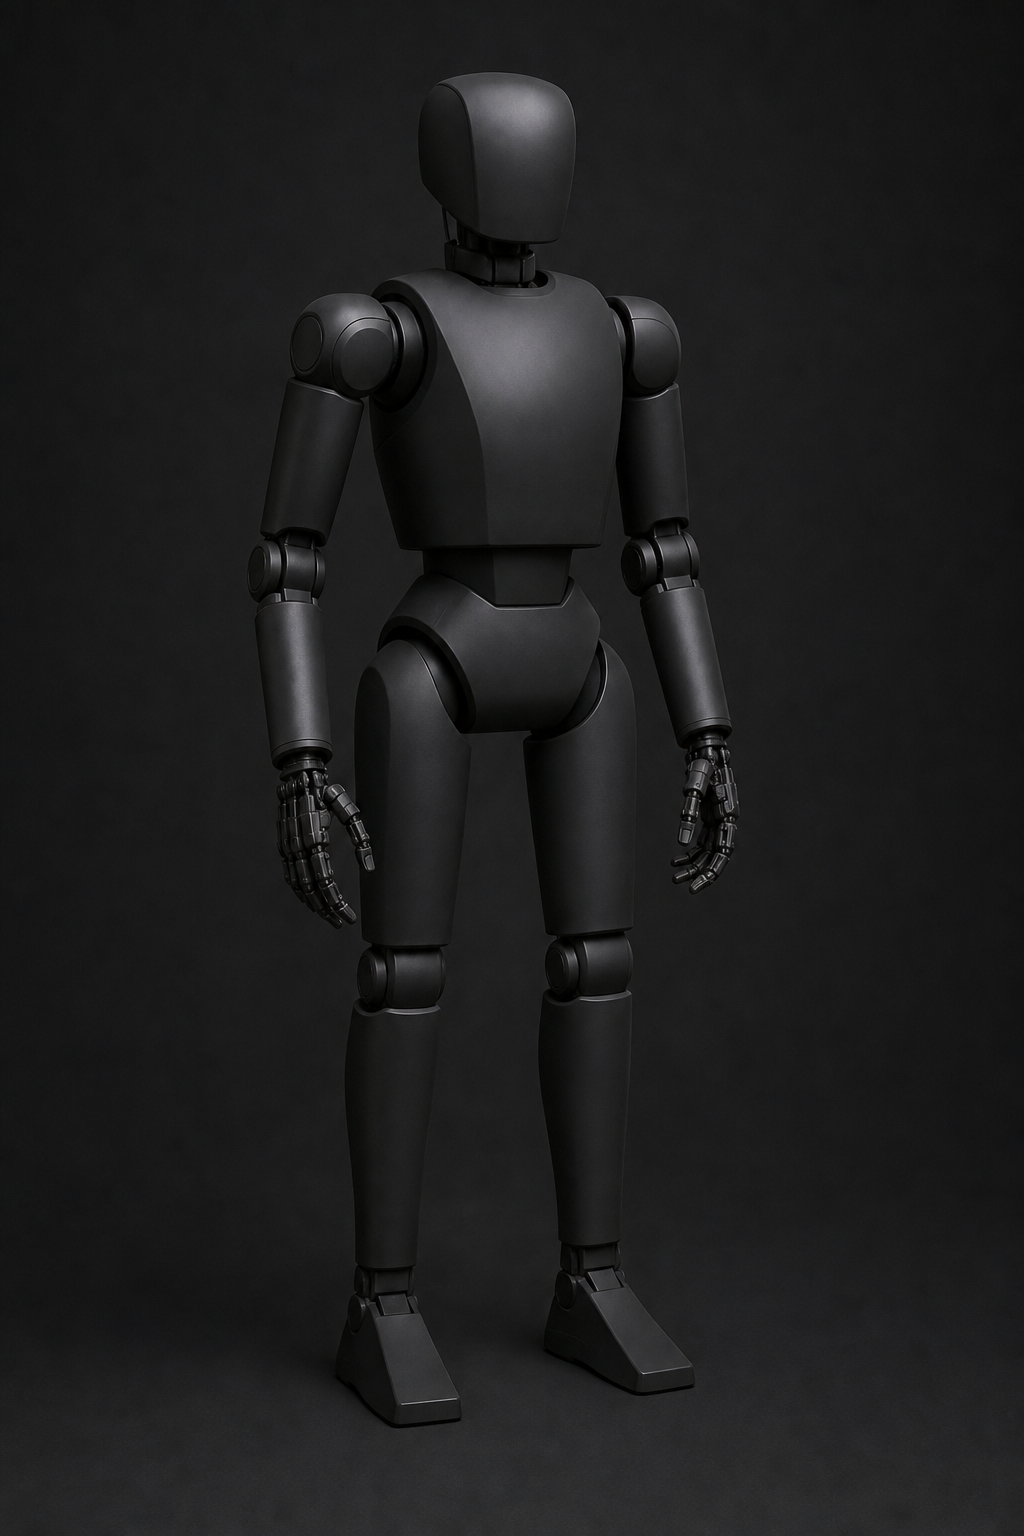
The FABER HAND — 22 DOF, human-level dexterity, full NEXUM sensor integration — is the primary product. It mounts to any commercial humanoid via ISO 9283 standard interface. AI MACHINAE does not require you to buy the body.
Primary Product
The FABER HAND.
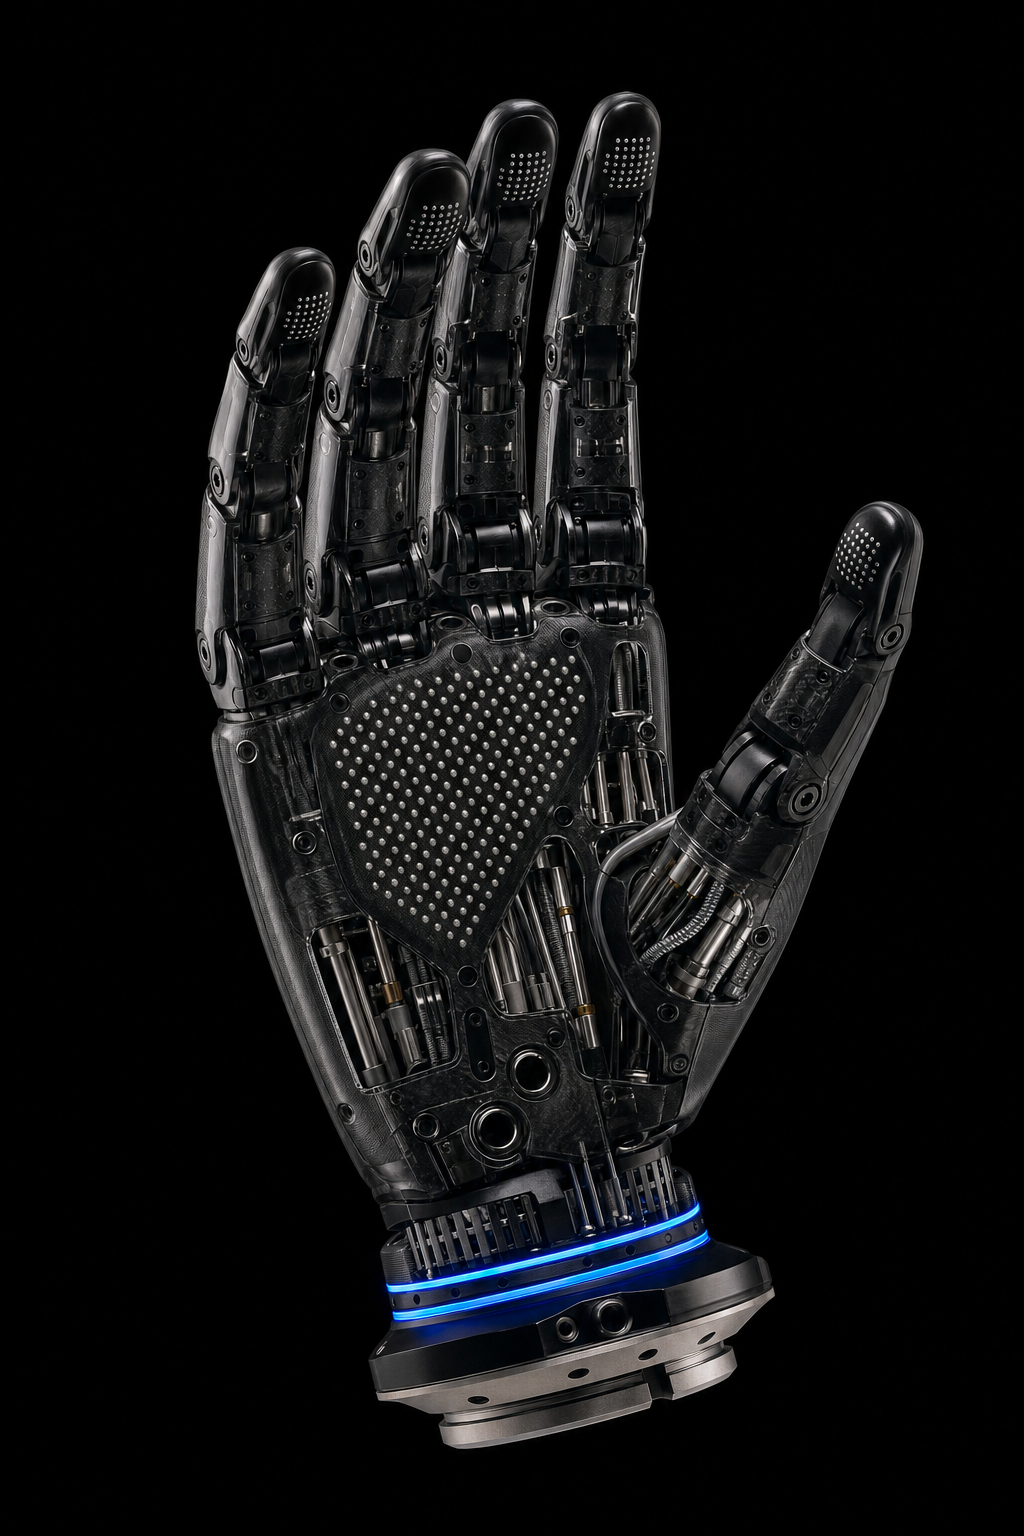
22 degrees of freedom. 576 tactile sensor points. Tendon-driven actuation that mirrors human musculature. The hand that makes FABER capable of any task a human worker can perform — and streams every force, torque, and surface interaction back to NEXUM in real time.
22DOF
Degrees of freedom
576pts
Tactile sensors
150N
Max grip force
15kg
Payload capacity
22 DOF — Human-level dexterity
Thumb opposition, four-finger abduction, and three-phalange flexion across all digits. Capable of the full range of human grip configurations: power, precision, pinch, key, hook, and lateral.
Full-hand tactile sensing
576 tactile sensor points across palm and fingertips. Real-time force distribution mapping enables slip detection, surface characterisation, and precision torque control on everyday fasteners and tools.
NEXUM sensor suite integration
FABER HAND streams force, torque, tactile, and tool-detection data to NEXUM continuously. The same sensor protocol runs across every machina in the fleet — consistent intelligence layer across every machine on the platform.
Hand Specifications
Full spec sheet.
Every joint. Every sensor. Every interface. FABER HAND is designed to be characterised completely — no black box hardware, full telemetry to NEXUM at all times.
Designation
FABER HAND v1
Total DOF
22
Thumb DOF
4 (flexion ×3 + opposition)
Finger DOF (×4)
3 each (flexion ×3)
Abduction DOF
4 (one per finger pair)
Wrist DOF
2 (flexion/extension + radial/ulnar)
Fingertip Force Resolution
±0.1 N
Max Grip Force
150 N (power grip)
Max Pinch Force
50 N (index-thumb)
Max Payload
15 kg (power grip)
Palm Tactile Array
256 sensor points
Fingertip Tactile
64 pts × 5 fingers = 320 total
Actuation
Tendon-driven — forearm actuator pack
Hand Mass
820 g
System Mass (with actuator pack)
1.4 kg
Ingress Protection
IP54
Operating Temperature
-10°C to 55°C
NEXUM Sensor Stream
Force, torque, tactile, tool-detection
The Body — Early Design
FABER v1.
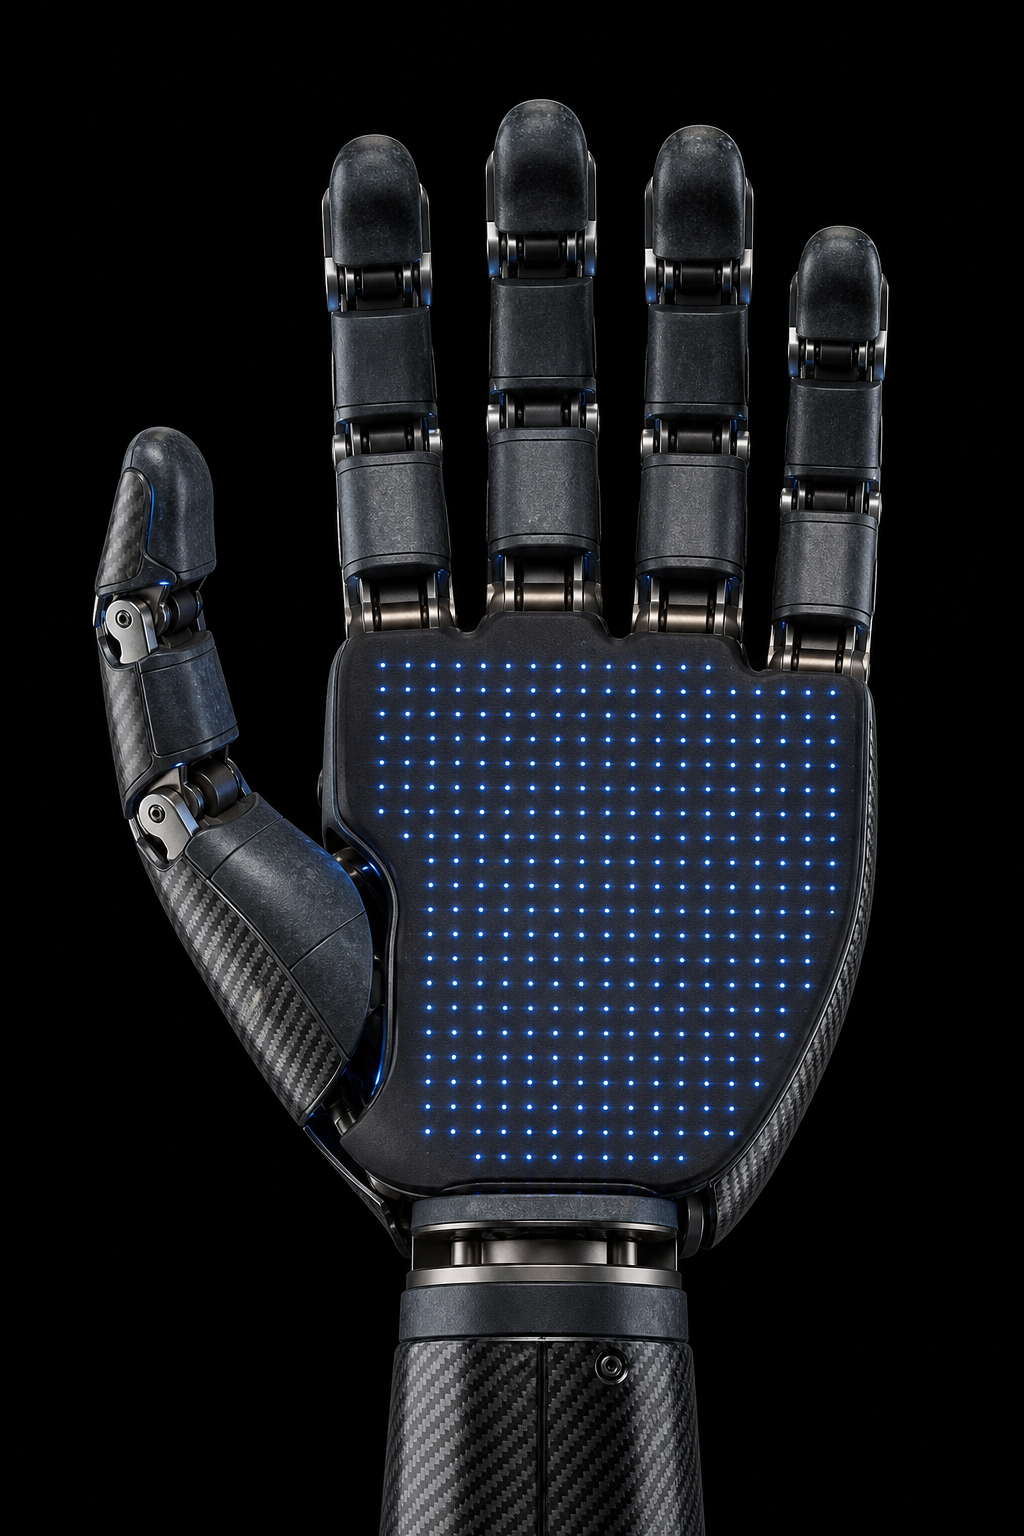
The reference platform for FABER HAND. Bipedal, designed for the places people work — uneven ground, confined spaces, working at height. Specifications below reflect early design targets. The hand ships first.
Designation
FABER v1 (body)
Configuration
Bipedal humanoid
Height
1.72 m
Mass
72 kg
Carry Payload
20 kg
Leg DOF
6 per leg
Locomotion
Bipedal — flat and uneven terrain
End Effector
FABER HAND v1 (standard)
Status
Early design phase
FABER v1 — BODY
[ CONCEPT DESIGN ]